
What Is a Drone Parachute Recovery System and How It Works: Technical Guide
What Is a Drone Parachute Recovery System and How It Works: Technical Guide
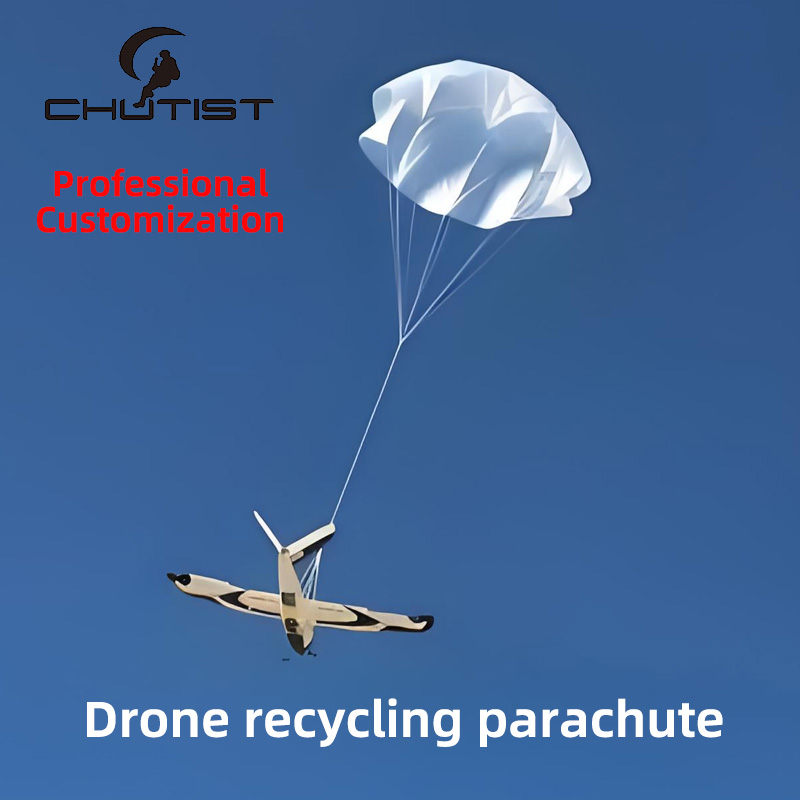
Unmanned aerial vehicles (UAVs) are increasingly used in industrial inspection, logistics, surveying, emergency response, and research testing. As payloads grow heavier and operational environments become more complex, the consequences of in-flight failure also increase. A drone parachute recovery system is designed to mitigate these risks by providing a controlled descent in the event of an emergency.
This technical guide explains what a drone parachute recovery system is, how it works, its key components, performance principles, and practical considerations for industrial and professional UAV applications.
What Is a Drone Parachute Recovery System?
A drone parachute recovery system is an onboard safety mechanism that deploys a parachute to reduce descent speed and impact energy when a UAV experiences a critical failure. Unlike standard landing systems, it is intended for emergency use only, activating when controlled flight is no longer possible.
Typical failure scenarios include:
Power loss or battery failure
Flight controller malfunction
Motor or propeller damage
Loss of communication link
Structural failure during testing or operation
By converting a free-fall event into a controlled vertical descent, the system helps protect:
The UAV airframe and payload
People and property on the ground
Sensitive test data and onboard sensors
Drone parachute recovery systems are widely used in industrial UAVs, research platforms, and increasingly in regulatory-compliant operations.
Why Drone Parachute Systems Are Important for UAV Safety
As UAV weights and operating altitudes increase, uncontrolled crashes present serious safety and compliance challenges. A parachute recovery system addresses these challenges in several ways:
Impact energy reduction: Lower descent velocity significantly reduces ground impact forces.
Operational risk mitigation: Helps meet internal safety requirements for industrial and research missions.
Asset protection: Reduces damage to high-value payloads such as LiDAR, cameras, or test equipment.
Regulatory alignment: Supports compliance with emerging aviation safety standards and risk assessments.
For heavy or mission-critical UAVs, a recovery parachute is often considered an essential safety layer rather than an optional accessory.
Core Components of a Drone Parachute Recovery System
A typical system consists of several integrated components, each with a specific function:
Parachute Canopy
The canopy is the primary load-bearing element. It is designed to generate sufficient drag to stabilize descent within a defined speed range. Key design factors include:
Fabric strength and tear resistance
Canopy shape (round, cruciform, or hybrid designs)
Porosity and airflow control
The canopy must withstand rapid opening forces while maintaining consistent performance across different weights.
Deployment Mechanism
The deployment system ensures rapid and reliable parachute extraction. Common mechanisms include:
Ballistic deployment: Uses a small pyrotechnic charge or compressed gas to eject the parachute quickly.
Spring-assisted deployment: Relies on mechanical energy stored in a spring system.
For low-altitude or high-speed UAVs, rapid deployment time is critical to ensure sufficient descent distance for canopy inflation.
Trigger and Control Unit
The trigger system determines when deployment occurs. Activation can be:
Automatic: Based on sensor inputs such as free-fall detection, attitude deviation, or power loss.
Manual: Triggered remotely by the operator in emergency situations.
Advanced systems integrate with the flight controller to avoid accidental deployment during normal maneuvers.
Structural Housing and Integration Hardware
The parachute assembly is housed in a protective container designed to:
Shield the system from vibration and environmental exposure
Ensure clean and unobstructed deployment
Minimize aerodynamic drag during normal flight
Proper integration with the UAV frame is essential to avoid asymmetric forces during deployment.
How a Drone Parachute Recovery System Works
The operational sequence of a drone parachute recovery system can be divided into several stages:
1. Failure Detection
Sensors or software algorithms detect abnormal flight conditions, such as:
Sudden loss of thrust
Uncontrolled angular acceleration
Power interruption
Exceeding defined flight envelope limits
Once thresholds are exceeded, the system transitions to emergency mode.
2. Deployment Activation
The trigger mechanism initiates parachute deployment. In ballistic systems, this typically occurs within milliseconds. Rapid activation is especially important for:
Low-altitude flights
High-speed industrial UAVs
Urban or confined operational areas
3. Canopy Extraction and Inflation
The parachute is ejected clear of the UAV structure, allowing the canopy to inflate. Design considerations at this stage include:
Minimizing line entanglement
Controlling opening shock loads
Achieving stable vertical alignment
Successful inflation converts downward velocity into aerodynamic drag.
4. Controlled Descent and Landing
Once fully deployed, the system stabilizes the UAV into a vertical descent at a reduced terminal velocity. The descent rate is calculated to keep impact forces within acceptable limits for the UAV and payload.
Key Performance Parameters Explained
Understanding performance metrics is critical when evaluating a drone parachute recovery system:
Load Capacity
The maximum supported weight includes:
UAV airframe
Payload
Recovery system mass
Design margins are typically applied to account for dynamic opening loads.
Deployment Altitude
Minimum deployment altitude determines whether the system can fully inflate before ground impact. Low-altitude extraction systems require faster deployment mechanisms and optimized canopy designs.
Descent Rate
Measured in meters per second, descent rate directly affects impact energy. Industrial systems aim to balance descent speed with canopy size and weight constraints.
Opening Shock
Opening shock refers to the transient force experienced during canopy inflation. Excessive shock can damage UAV structures, making controlled deployment design essential.
Integration Considerations for Industrial UAVs
Installing a parachute recovery system involves more than mounting hardware. Key considerations include:
Center of gravity alignment: Prevents instability during descent.
Electrical integration: Ensures reliable power and signal routing.
Flight control compatibility: Avoids interference with normal operations.
Maintenance accessibility: Allows inspection and repacking after testing or deployment.
System integration should be validated through ground and flight testing.
Testing and Validation Methods
Reliable systems undergo extensive validation, including:
Ground deployment tests
Drop tests at representative weights
Environmental testing for temperature and vibration
Repeated packing and deployment cycles
Experienced manufacturers often design systems based on data from hundreds or thousands of test deployments. In China’s UAV sector, suppliers such as Nanjing Hongguang General Aviation Equipment Technology Co., Ltd. have developed recovery systems covering a wide range of UAV weights and operating conditions through long-term testing and national-level aviation projects.
Typical Application Scenarios
Drone parachute recovery systems are commonly used in:
Industrial inspection UAVs operating over infrastructure
Research and development test platforms
Emergency response and public safety drones
Heavy-lift or long-endurance UAVs
Urban or population-adjacent operations
In these scenarios, recovery systems function as a passive safety layer rather than a routine operational tool.
Common Misconceptions
Several misconceptions often arise when evaluating parachute recovery systems:
“Small drones do not need parachutes.”
Even lightweight UAVs can pose safety risks in certain environments.“Parachutes guarantee zero damage.”
The goal is impact energy reduction, not absolute damage elimination.“Any parachute fits any drone.”
Weight, speed, and deployment altitude must be carefully matched.
Understanding these limitations helps set realistic expectations.
A drone parachute recovery system is a critical safety technology designed to reduce the risks associated with UAV failures. By combining rapid deployment mechanisms, carefully engineered parachute canopies, and intelligent triggering systems, it transforms uncontrolled crashes into controlled descents.
For industrial, research, and professional UAV operations, understanding how these systems work—and how to select and integrate them correctly—is essential for improving safety, protecting assets, and supporting regulatory compliance. Over time, as UAV operations continue to expand, parachute recovery systems are likely to become a standard component in advanced drone safety architectures rather than an optional add-on.


